Selected Projects
Connecting software with physical systems.
From industrial robots to autonomous ocean monitoring and spacecraft operations, these are some of the projects that have shaped how I think about systems engineering.
Autonomous Marine Robotics
2025–2026
MANTARAY Profiler
Senior design and research project focused on a low-cost autonomous ocean-monitoring platform designed to navigate surface waypoints, perform vertical profiling maneuvers, and collect environmental data throughout the water column.
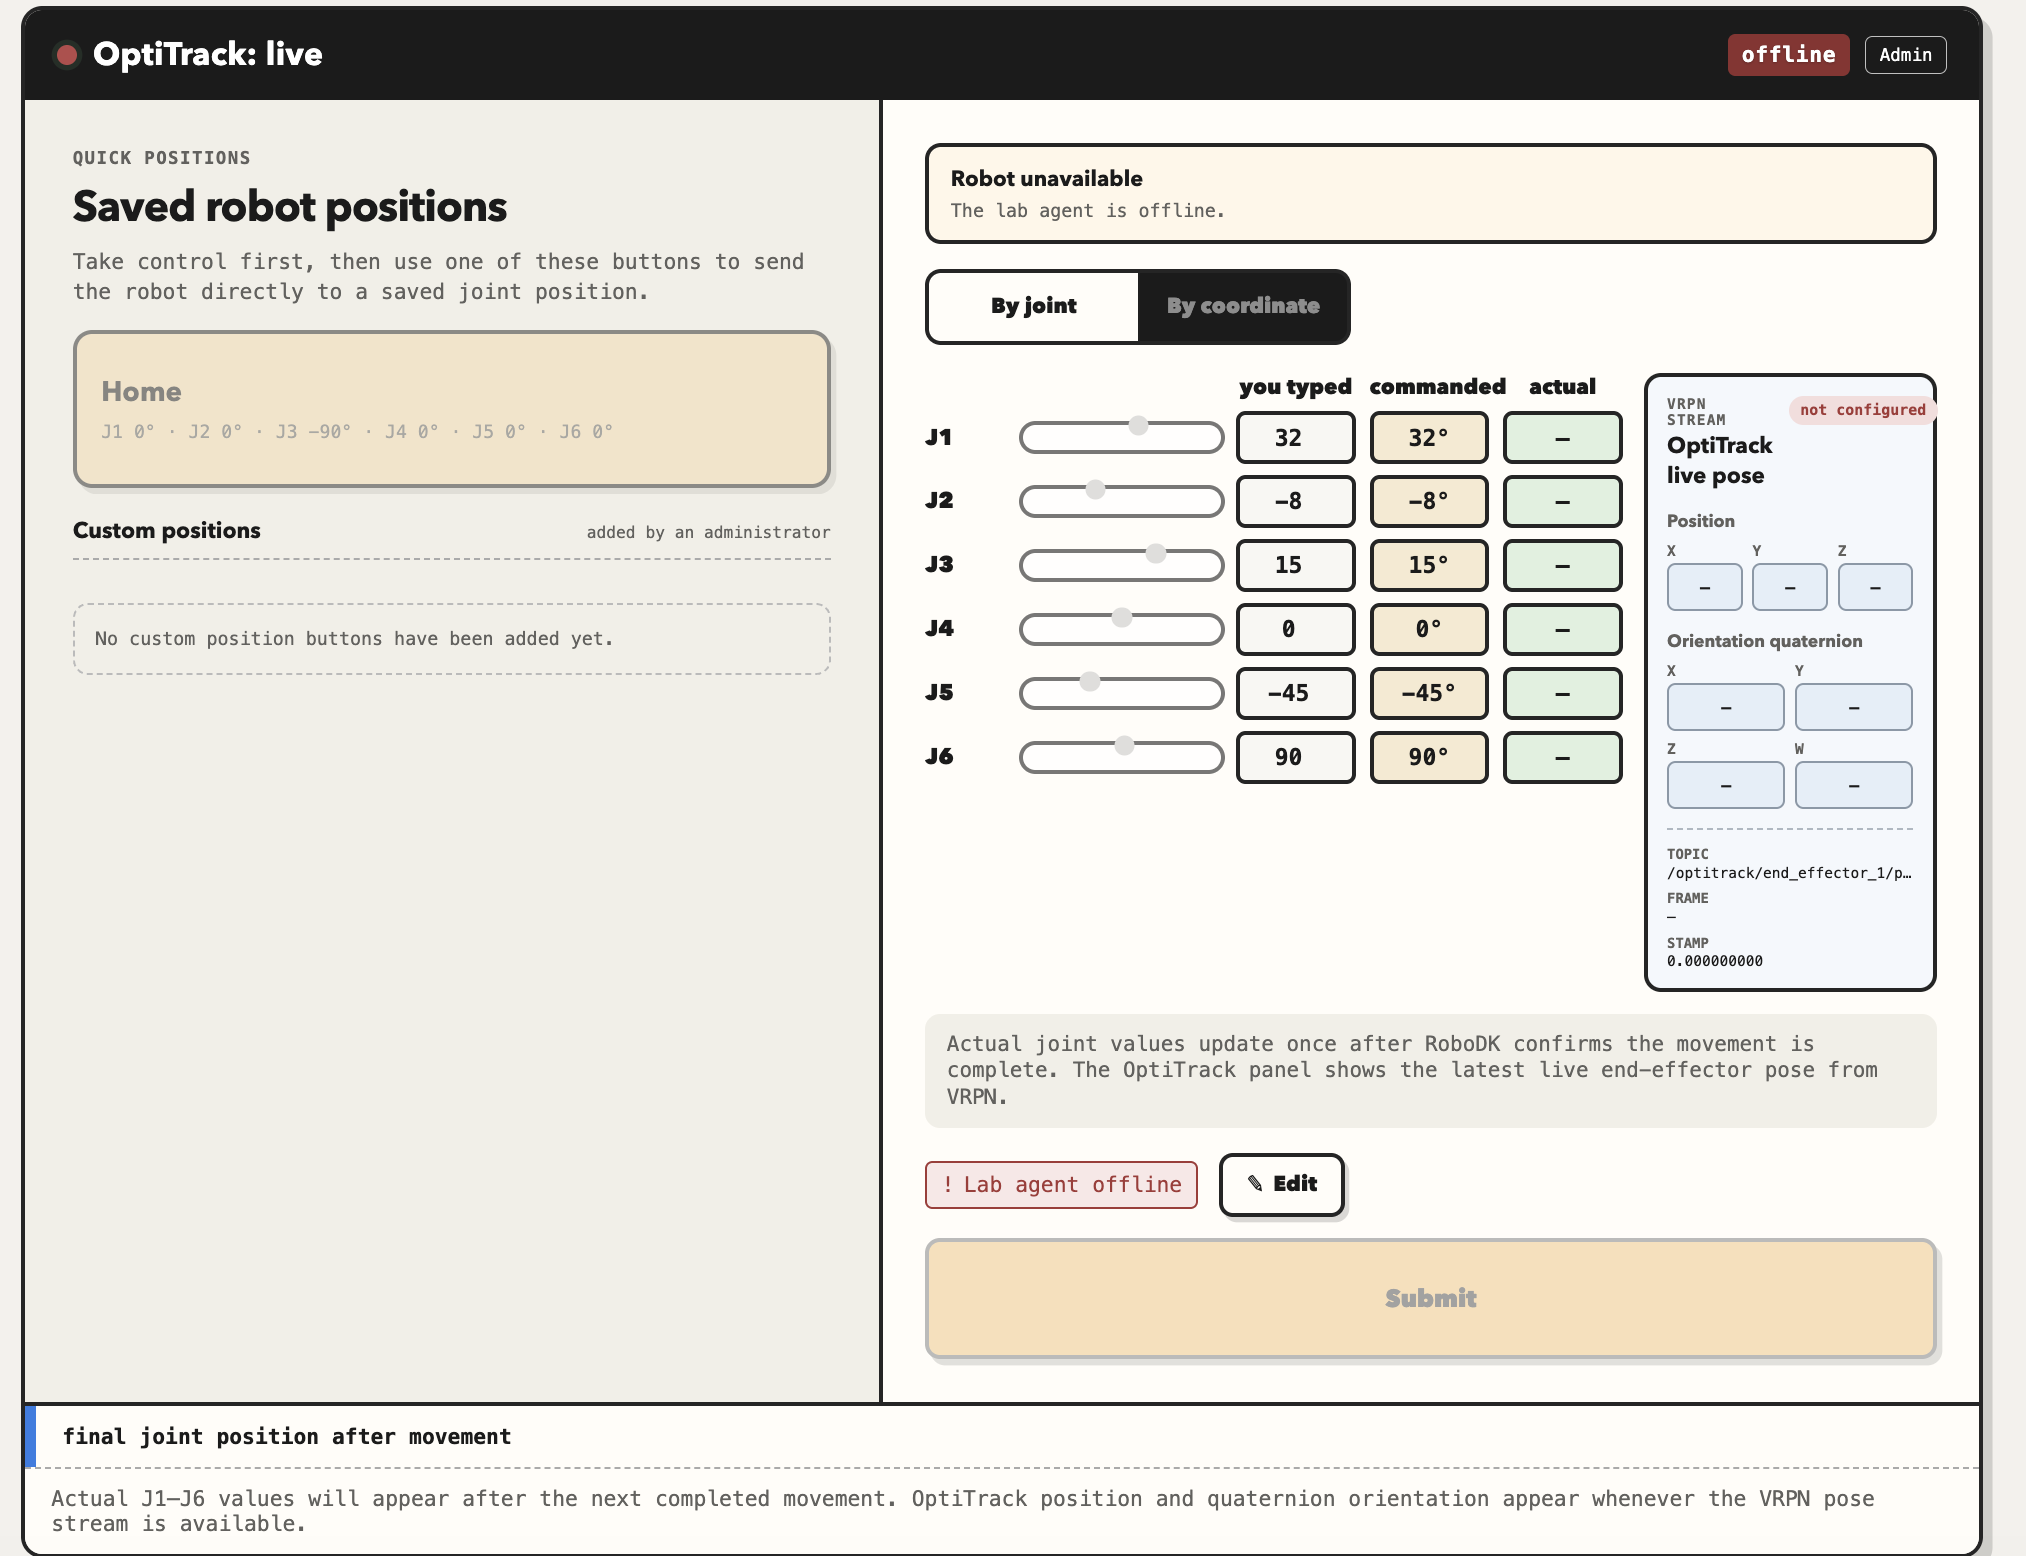
I developed the graphical user interface used to configure missions and interact with the profiler, and worked with the software team on integration and autonomous-navigation testing. Earlier work on the profiler also included contributions to bidirectional communication and GPS integration.
GUI DevelopmentSystem IntegrationGPSEnvironmental SensingTesting
Read the Senior Design Thesis
Spacecraft Mission Operations
NASA ACS3
Advanced Composite Solar Sail System
Supported mission control operations for NASA's ACS3 mission through the SCU Robotic Systems Lab, including satellite tracking and contact execution.
The ACS3 Mission Operation and Engineering Team was recognized with a 2025 NASA Ames Honor Award, of which I was a co-recipient, for the team's performance and support of the successful solar-sail deployment.
Mission OperationsSatellite TrackingContact ExecutionTeam Operations
Robotics Education & Documentation
2026–Present
ROS Badge / MyCobot Activities
Collaborating with the RSL team on a ROS training pathway that uses a physical MyCobot robot to connect software concepts with hands-on robot activities.
My work includes MyCobot-related responsibilities and helping identify, organize, and document the commands and reference material learners need when moving from simulated examples to a real robot.
ROSMyCobotTechnical DocumentationTraining Design